CableBot Lab · Tsinghua University

索驱机器人与智能装备

Cable-Driven Robotics& Intelligent Equipment

面向大空间、高负载、轻量化作业场景,
开展索驱机器人基础理论、核心技术与工程应用研究。

  • 机构与构型设计

    Mechanism Design

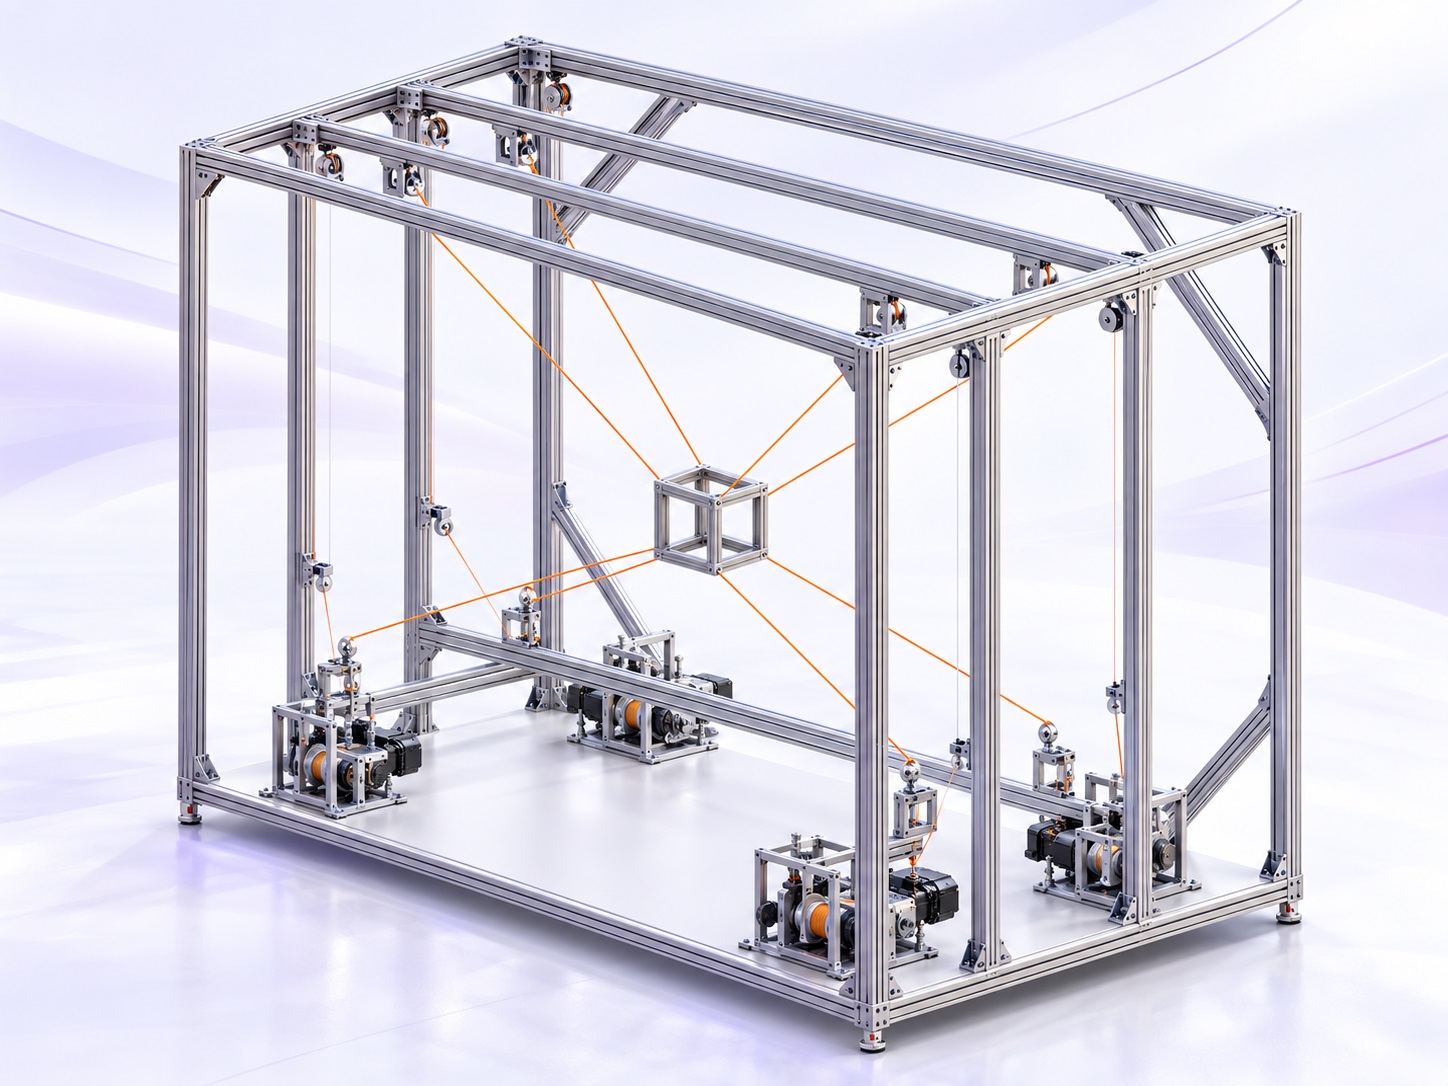
    Cable-driven robot mechanism and configuration illustration

    索驱机构构型、力学分析与优化设计

  • 建模与动力学

    Modeling & Dynamics

    Cable-driven robot modeling and dynamics surface illustration

    系统建模、动力学分析与仿真

  • 运动与协调控制

    Motion Control & Coordination

    Cable-driven robot motion control and coordination illustration

    运动规划、多机器人协同与智能控制

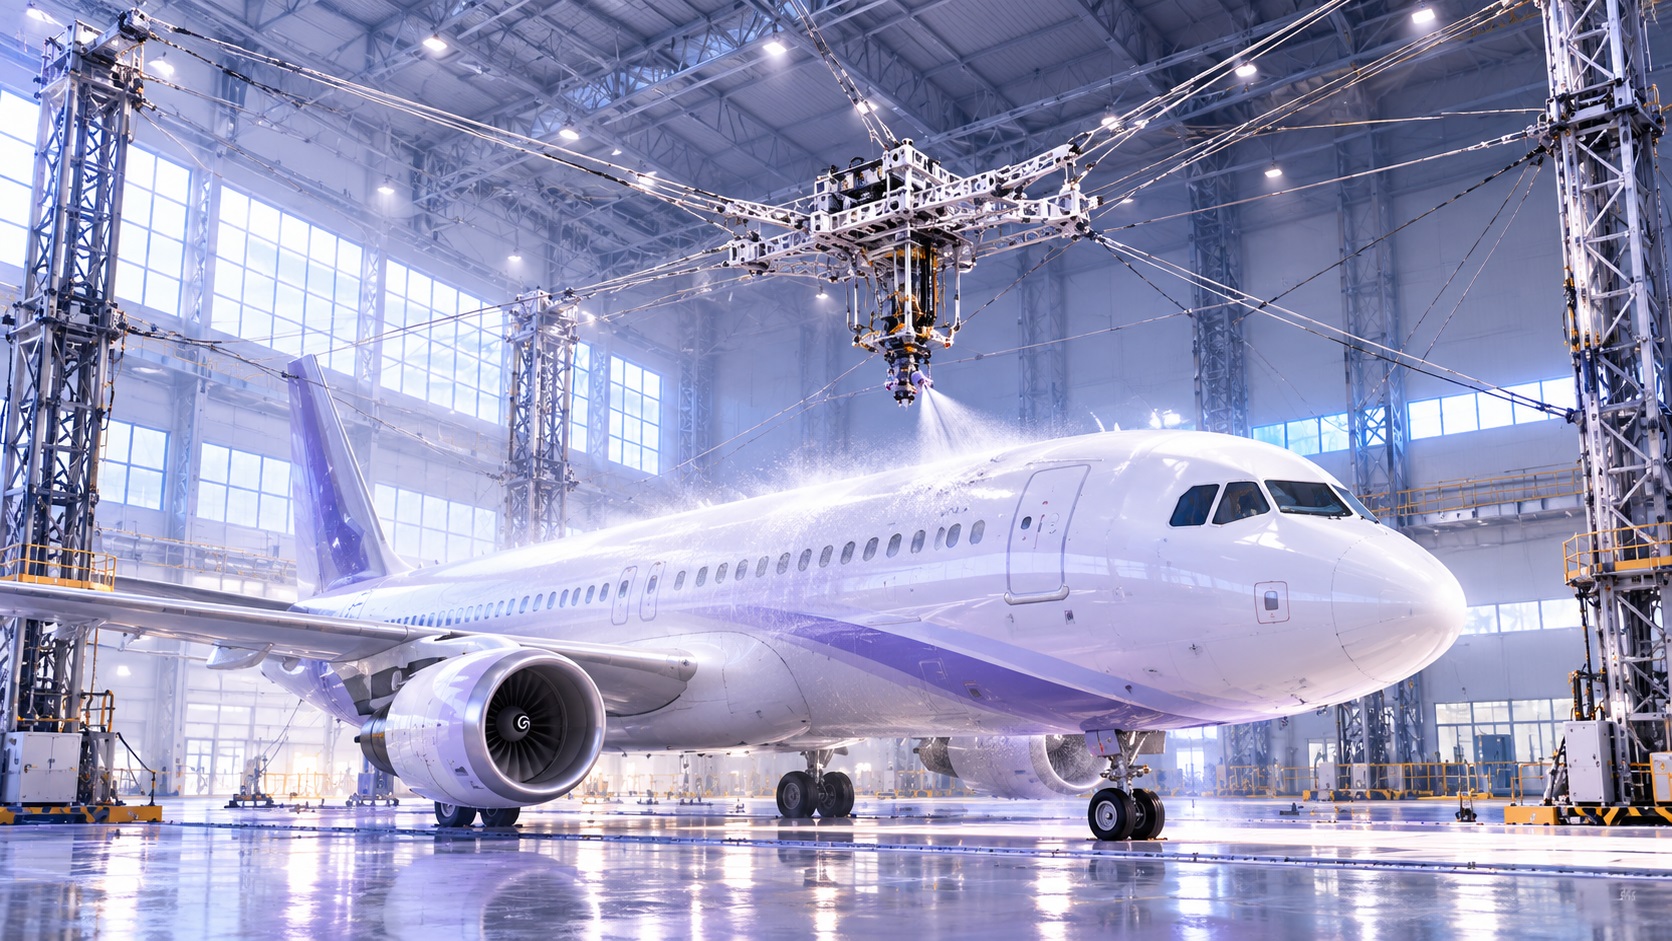
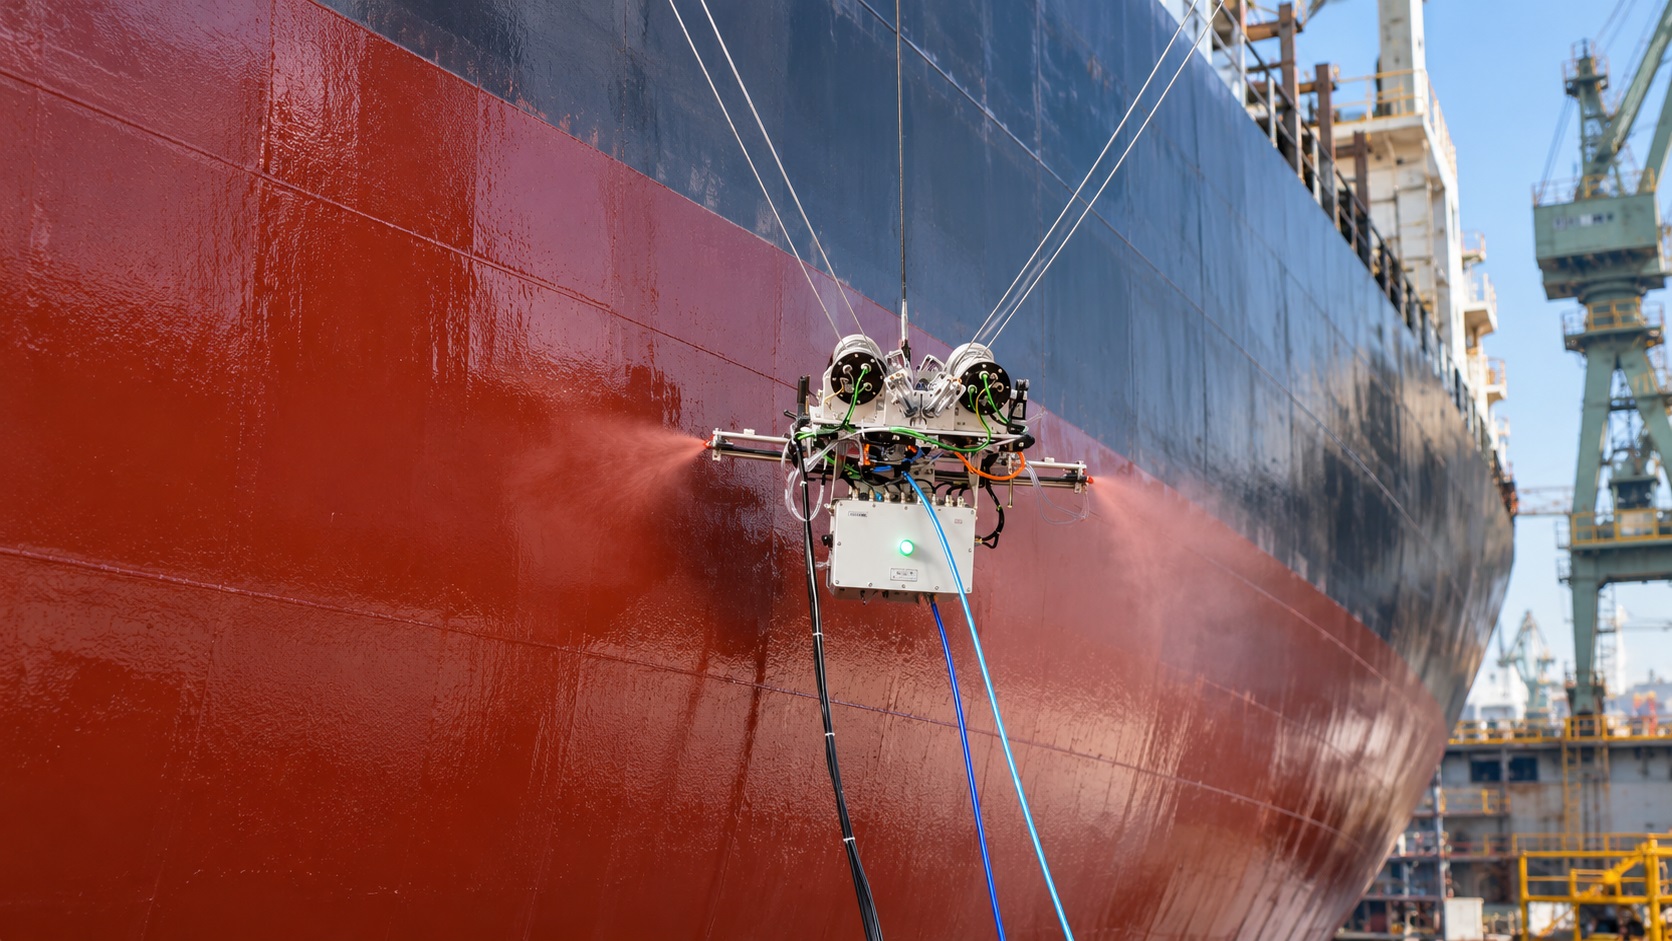
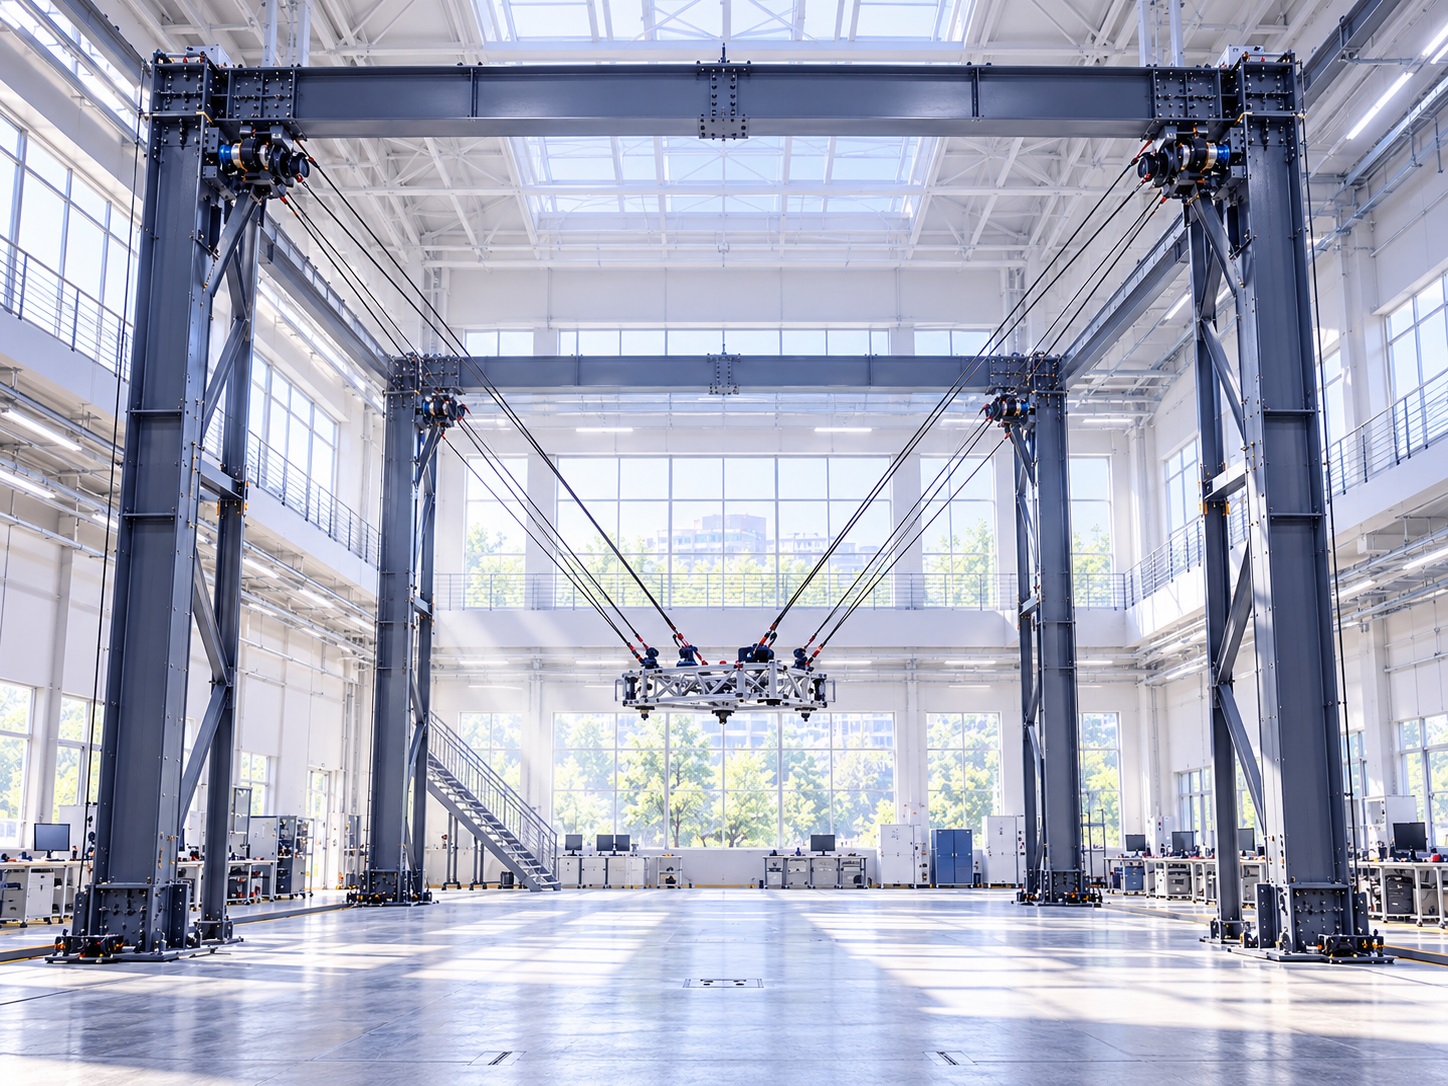
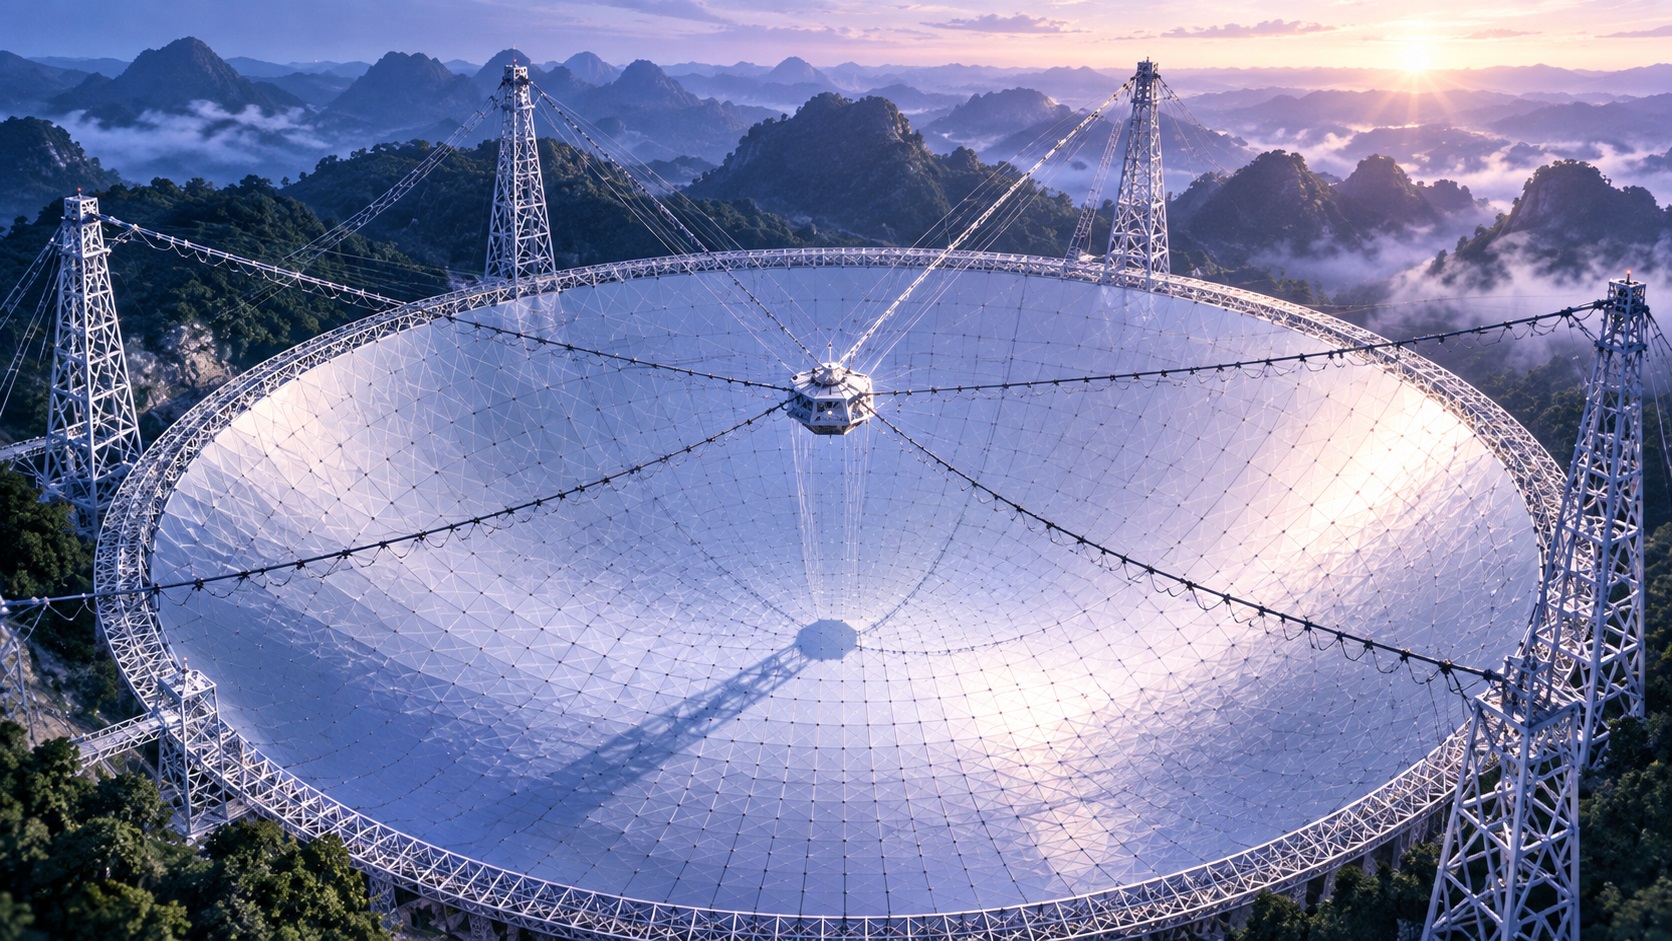
  • Large-span cable-driven robot in engineering test environment

    大跨度索驱机器人

    →

    Large-Span Cable-Driven Robot

    • 大工作空间
    • 高承载能力
    • 工程应用
  • 高速索驱并联机器人

    →

    High-Speed Cable-Driven Parallel Robot

    • 高速运动
    • 轻量化设计
    • 高精度控制
  • Modular reconfigurable cable-driven parallel robot structure

    模块化可重构索并联机器人

    →

    Modular Reconfigurable Cable-Driven Robot

    • 模块化设计
    • 可重构构型
    • 多任务拓展
  • 67

    期刊论文

    Journal Papers

  • 60

    授权专利

    Authorized Patents

  • 8

    标准

    Standards

  • 20

    软著

    Software

  • 17

    获奖

    Awards

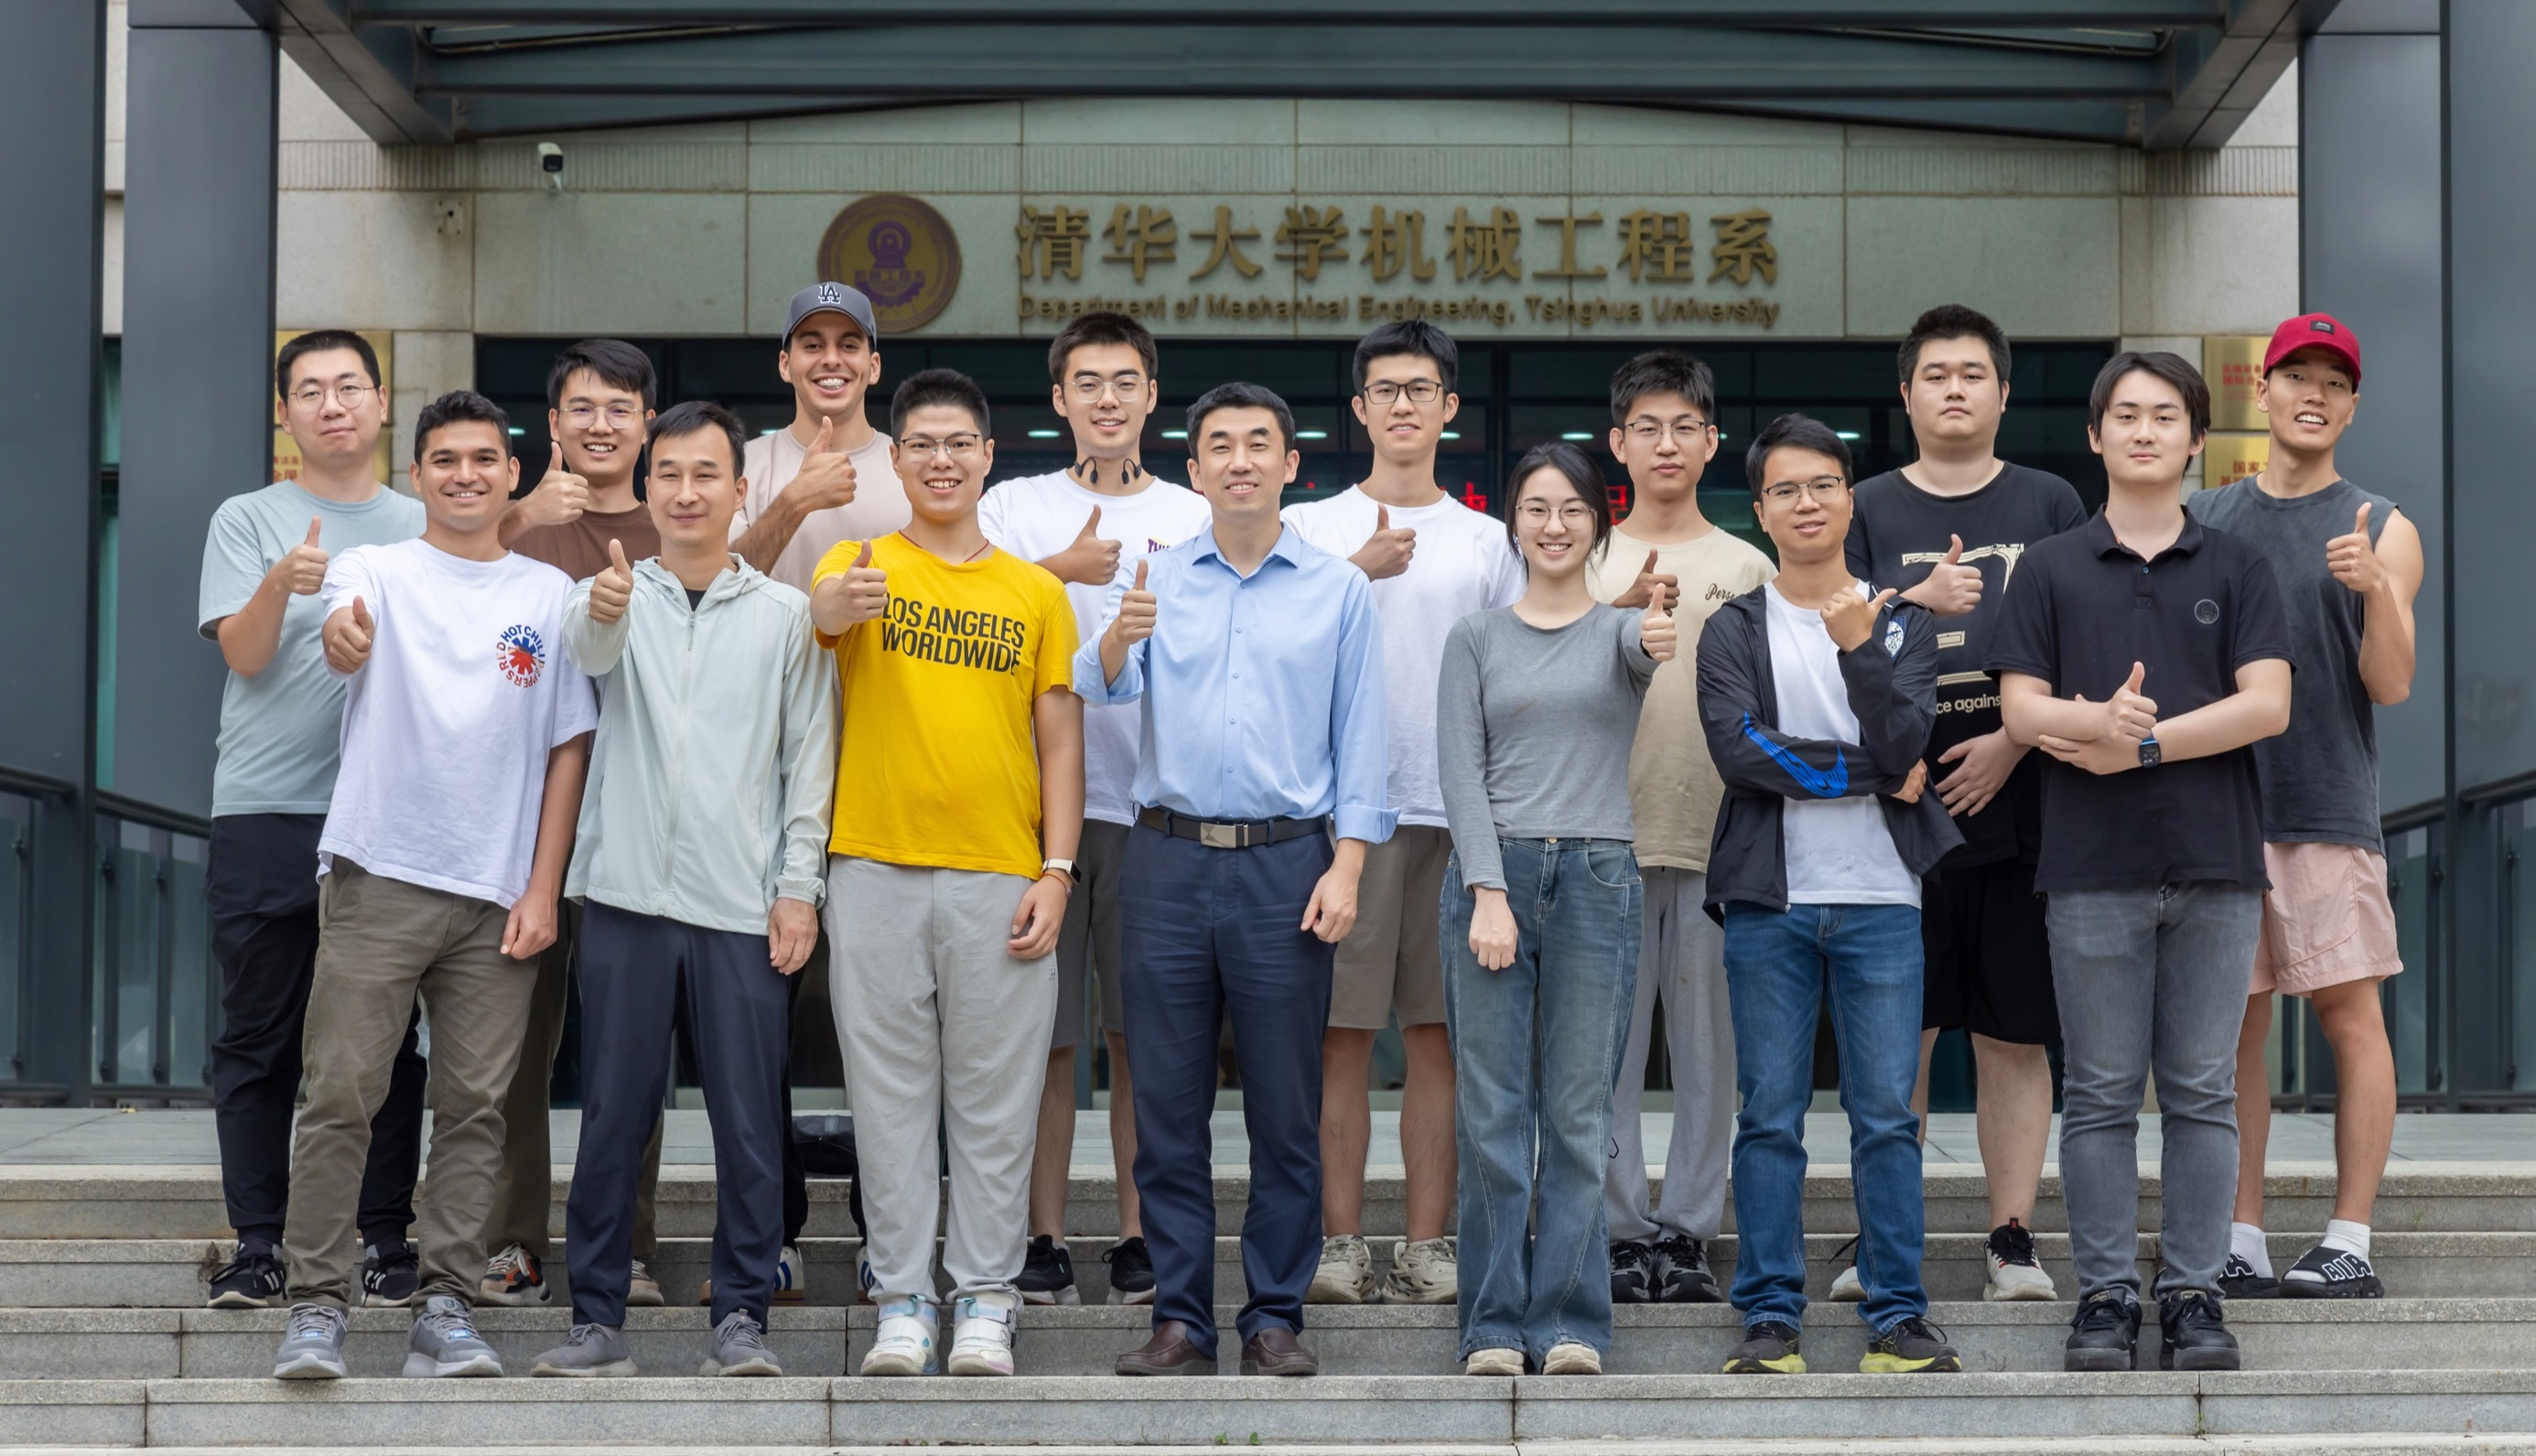
CableBot Lab research team group photo with Tsinghua University Department of Mechanical Engineering backdrop