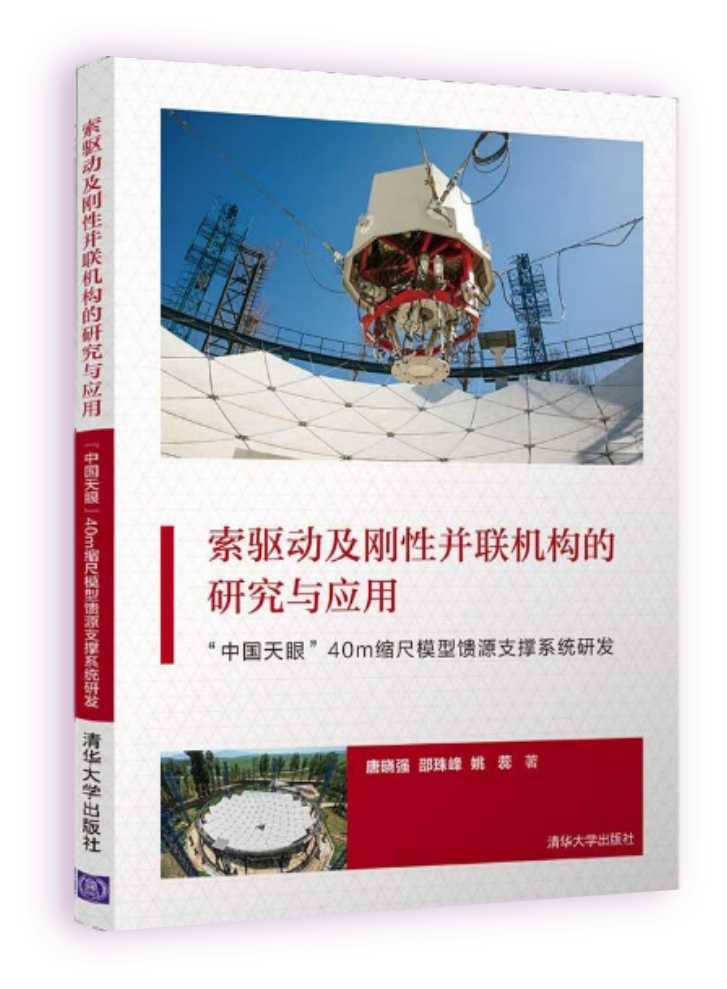
索驱动及刚性并联机构的研究与应用
清华大学出版社 · 2020
围绕索驱动及刚性并联机构的基础理论、分析方法及工程应用展开系统论述。
Publications
围绕索驱并联机器人、并联机构、机器人动力学与控制及工程应用,持续开展科研工作并形成系列论文、标准、专著和科技成果。
Duan Jinhao, Liu Hanqing, Zhang Zhaokun, Shao Zhufeng*, Meng Xiangjun, Lv Jingang, Huang Minjian. Reconfiguration and Performance Evaluation of TBot Cable-Driven Parallel Robot[J]. 2025, 17(1): 010909. DOI: 10.1115/1.4065680.
Duan Jinhao, Liu Hanqing, Yan Le, Shao Zhufeng*, Zhang Zhaokun, Tang Xiaoqiang, Huang Minjian, Peng Zixiang. Enhancing anti-disturbance performance of redundant cable-driven parallel robots: Analysis and tension distribution method [J]. Mech Mach Theory, 2025, 205: 23. DOI: 10.1016/j.mechmachtheory.2024.105861.
Liu Yuhang, Zheng Yuqiao, Shao Zhufeng, Wei Tai, Cui Tiancai, Xu Rong, Defect detection of the surface of wind turbine blades combining attention mechanism[J]. Advanced Engineering Informatics, 2024, 59. DOI: 10.1016/j.aei.2023.102292.
Liu Zhihua, Cai Chenguang, Yang Ming, Shao Zhufeng*, Lv Qi. A Numerical Approximation Approach for Deriving Computational Efficient Inverse Dynamics of 6-DOF Parallel Robots Based on Principle of Virtual Work[J]. 2024, 9(6): 5966-5973. DOI: 10.1109/LRA.2024.3397535.
Duan Jinhao, Liu Hanqing, Shao Zhufeng*, Yao Rui, Zhang Zhaokun, Caro Stephane. Anti-disturbance performance analysis and the innovative design of the FAST fine-tuning platform[J]. 2024, 197: 105645. DOI: 10.1016/j.mechmachtheory.2024.105645.
Liu Hanqing, Duan Jinhao, Shao Zhufeng*, Caro Stephane. Torque Resistance Analysis and Dynamic Trajectory Planning for 3-DOF Cable Suspended Parallel Robot with Parallelogram Cable Loops[J]. 2024, 9(7): 6296-6303. DOI: 10.1109/LRA.2024.3402190.
Huo Ye, Khan, Muhammad Niaz, Shao Zhufeng*, Pan Yu. Development of a novel cable-driven parallel robot for full-cycle ankle rehabilitation[J]. 2024, 101: 103210. DOI: 10.1016/j.mechatronics.2024.103210.
Yao Ming, Zhou Xiang, Shao Zhufeng*, Wang Liping. A general energy modeling network for serial industrial robots integrating physical mechanism priors[J]. 2024, 89: 102761. DOI: 10.1016/j.rcim.2024.102761.
Yao Ming, Shao Zhufeng*, Su Yunzhou, Wei Dehao, Zhang Fumin, Wang Liping. CRTF-MoeICP: A robust coarse-to-fine reflector-based LiDAR indoor positioning algorithm [J]. Mechatronics, 2024, 104: 13. DOI: 10.1016/j.mechatronics.2024.103259.
Shao Zhufeng*, Zhang Dan, Caro Stéphane. New frontiers in parallel robots[J]. Machines, 2023, 11(3). DOI: 10.3390/machines11030386.
Qie Jinbo, Miao Yugang, Liu Huiju, Han Tao, Shao Zhufeng, Duan Jinhao. Design and process planning of non-structured surface spray equipment for ultra-large spaces in ship section manufacturing[J]. Journal of Marine Science and Engineering, 2023, 11(9). DOI: 10.3390/jmse11091723.
Zhang Zhaokun, Xie Guangqiang, Shao Zhufeng*, Clément Gosselin. Kinematic Calibration of Cable-Driven Parallel Robots Considering the Pulley Kinematics[J]. Mechanism and Machine Theory. 2022, 169:104648. DOI: 10.1016/j.mechmachtheory.2021.104648.
Duan Jinhao, Shao Zhufeng*, Zhang Zhaokun, Peng Fazhong. Performance Simulation and Energetic Analysis of TBot High-Speed Cable-Driven Parallel Robot[J]. Journal of Mechanisms and Robotics, 2022, 14(2):024504. DOI: 10.1115/1.4052322.
Xie Guangqiang, Zhang Zhaokun, Shao Zhufeng*, Wang Liping. Research on the Orientation Error of the Translational Cable-Driven Parallel Robots[J]. Journal of Mechanisms and Robotics, 2022, 14(3):031003. DOI: https://doi.org/10.1115/1.4052848.
Zhaokun Zhang, Guangqiang Xie, Zhufeng Shao*, Clément Gosselin. Kinematic Calibration of Cable-Driven Parallel Robots Considering the Pulley Kinematics[J]. Mechanism and Machine Theory. 2022, 169:104648. March 1, 2022. DOI: 10.1016/j.mechmachtheory.2021.104648.
Zhaokun Zhang, Zhufeng Shao*, Zheng You, Xiaoqiang Tang, Bin Zi, Guilin Yang, Clément Gosslin, Stéphane Caro. State-of-the-art on theories and applications of cable-driven parallel robots[J]. Frontiers of Mechanical Engineering, 2022, 17(3). DOI: 10.1007/s11465-022-0693-3.
Shao Zhufeng, Xie Guangqiang, Zhang Zhaokun* and Wang Liping. Design and analysis of the cable-driven parallel robot for cleaning exterior wall of buildings. International Journal of Advanced Robotic Systems. 2021, 18(1): 1-11. DOI:10.1177/1729881421990313.
Amin Lotfiani, Yi Xili, Shao Zhufeng*, Zhao Huichan, A.Nouri Parkestani. Analytical modelling and optimization of a corrugated soft pneumatic finger considering the performance of pinch and power grasps. Extreme Mechanics Letters. 2021, 44:101215. DOI: 10.1016/j.eml.2021.101215.
Lotfiani Amin, Zhao Huichan, Shao Zhufeng*, Yi Xili. Torsional Stiffness Improvement of a Soft Pneumatic Finger Using Embedded Skeleton. Journal of Mechanisms and Robotics, 2020, 12(1):011016. October 31, 2019, DOI: 10.1115/1.4045227.
Zhang Zhaokun, Shao Zhufeng*, Wang Liping. Optimization and implementation of a high-speed 3-DOFs translational cable-driven parallel robot. Mechanism and Machine Theory, 2020, 145, 103693. DOI: 10.1016/j.mechmachtheory.2019.103693.
Zhang Zhaokun, Shao Zhufeng*, Peng Fazhong, Li Haisheng, Wang Liping. Workspace Analysis and Optimal Design of a Translational CDPR with Passive Springs. Journal of Mechanisms and Robotics, 2020, 12(5): 051005. March 13, 2020, DOI: 10.1115/1.4046030.
Sun Zheng*, Shao Zhufeng, Li Hui. An Eikonal Equation Based Path Planning Method Using Polygon Decomposition and Curve Evolution, Defence Technology, 2020, 16(5): 1001-1018. DOI: 10.1016/j.dt.2019.12.005.
Shao Zhufeng, Li Haisheng, Wang Liping, Zhang Zhaokun, Yao Rui, Qie Jinbo. Orientation Optimization of Cable-driven Parallel Manipulator for Cleaning the Deep Sea Fishing Ground, International Journal of Robotics and Automation. 2020, 35(5): 347-354. DOI: 10.2316/J.2020.206-0316.
Ganjefar Soheil, Sarajchi Mohammad Hadi, Hoseini Seyed Mahmoud, Shao Zhufeng*. Lambert W Function Controller Design for Teleoperation Systems. International Journal of Precision Engineering and Manufacturing. 2019, 20(1):101-110. DOI: 10.1007/s12541-019-00018-y.
Wang Liping, Zhang Zhaokun, Shao Zhufeng*. Kinematic performance analysis and promotion of a spatial 3-RPaS parallel manipulator with multiple actuation modes, Journal of Mechanical Science and Technology. 2019, 33 (2), 889-902. DOI: 10.1007/s12206-019-0146-z.
Wang Liping, Zhang Zhaokun, Shao Zhufeng*, Tang Xiaoqiang. Analysis and optimization of a novel planar 5R parallel mechanism with variable actuation modes. Robotics and Computer-Integrated Manufacturing. 2019, 56, 178-190. DOI: 10.1016/j.rcim.2018.09.010.
Sarajchi Mohammad Hadi, Ganjefar Soheil, Hoseini Seyed Mahmoud, Shao Zhufeng*. Adaptive Controller Design Based on Predicted Time-delay for Teleoperation Systems Using Lambert W function. International Journal of Control, Automation and Systems. 2019, 17 (6), 1445-1453. DOI: 10.1007/s12555-018-0289-1.
Shao Zhufeng, Li Tiemin, Tang Xiaoqiang*, Tang Lewei, Deng Hao. Research on the dynamic trajectory of spatial cable-suspended parallel manipulators with actuation redundancy. Mechatronics, 2018, 49:26-35. DOI: 10.1016/j.mechatronics.2017.11.001.
Wang Liping, Chen Lian, Shao Zhufeng*, Guan Liwen, Du Li. Analysis of flexible supported industrial robot on terminal accuracy. International Journal of Advanced Robotic Systems, 2018, 15(4):1-12. DOI: 10.1177/1729881418793022.
Zhang Zhaokun, Wang Liping, Shao Zhufeng*. Improving the kinematic performance of a planar 3-RRR parallel manipulator through actuation mode conversion. Mechanism and Machine Theory, 2018, 130:86-108. DOI: 10.1016/j.mechmachtheory.2018.08.011.
Ganjefar Soheil, Afshar Mohammad, Sarajchi Mohammad Hadi, Shao Zhufeng*. Controller Design Based On Wavelet Neural Adaptive Proportional Plus Conventional Integral-Derivative For Bilateral Teleoperation Systems With Time-Varying Parameters. International Journal of Control Automation and Systems, 2018, 16(5):2405-2420. DOI: 10.1007/s12555-017-0739-1.
Staicu Stefan, Shao Zhufeng*, Zhang Zhaokun, Tang Xiaoqiang, Wang Liping. Kinematic analysis of the X4 translational–rotational parallel robot, International Journal of Advanced Robotic Systems. 2018, 15(5):1729881418803849. DOI: 10.1177/1729881418803849.
Mo Jiao, Shao Zhu-Feng*, Guan Liwen, Xie Fugui, Tang Xiaoqiang. Dynamic performance analysis of the X4 high-speed pick-and-place parallel robot. Robotics and Computer-Integrated Manufacturing, 2017, 46:48-57. DOI: 10.1016/j.rcim.2016.11.003.
Shao Zhu-Feng*, Mo Jiao, Tang Xiao-Qiang, Wang Li-Ping. Transmission Index Research of Parallel Manipulators Based on Matrix Orthogonal Degree. Chinese Journal of Mechanical Engineering, 2017, 30(6):1396-1405. DOI: 10.1007/s10033-017-0193-2.
Liu Zhihua, Tang Xiaoqiang*, Shao Zhufeng, Wang Liping. Dimensional optimization of the Stewart platform based on inertia decoupling characteristic. Robotica, 2016, 34(5):1-17. DOI: 10.1017/S0263574714002112.
Wang Weifang, Tang Xiaoqiang, Shao Zhuefng, Yang Jiping*, Yi Wangmin. Design and Analysis of a Wire-Driven Parallel Mechanism for Low-Gravity Environment Simulation. Advances in Mechanical Engineering, 2015, 6(1):810606. DOI: 10.1155/2014/810606.
Shao Zhu-Feng*, Tang Xiaoqiang, Yi Wangmin. Optimal Design of a 3-DOF Cable-Driven Upper Arm Exoskeleton. Advances in Mechanical Engineering, 2015, 6(1):157096. DOI: 10.1155/2014/157096.
Shao Zhufeng, Tang Xiaoqiang*, Wang Liping. Dynamics Verification Experiment of the Stewart Parallel Manipulator. International Journal of Advanced Robotic Systems, 2015, 12:144. DOI: 10.5772/61541.
Shao Zhufeng, Tang Xiaoqiang*, Wang Liping, Sun Dengfeng. Atlas Based Kinematic Optimum Design of the Stewart Parallel Manipulator. Chinese Journal of Mechanical Engineering, 2015, 28(1):20-28. DOI: 10.3901/CJME.2014.0929.155.
Tang Xiaoqiang*, Chai Xiaoming, Tang Lewei, Shao Zhufeng. Accuracy synthesis of a multi-level hybrid positioning mechanism for the feed support system in FAST. Robotics and Computer-Integrated Manufacturing, 2014, 30(5):565-575. DOI: 10.1016/j.rcim.2014.03.002.
Tang Xiaoqiang*, Liu Zhihua, Shao Zhufeng, Wang Liping. Self-excited vibration analysis for the feed support system in FAST[J]. International Journal of Advanced Robotic Systems, 2014, 11. DOI: 10.5772/58521.
Tang Xiaoqiang*, Shao Zhufeng. Trajectory generation and tracking control of a multi-level hybrid support manipulator in FAST. Mechatronics, 2013, 23(8):1113-1122. DOI: 10.1016/j.mechatronics.2013.09.002 (SCI, EI)
Tang Xiaoqiang*, Sun Dengfeng, Shao Zhufeng. The Structure and Dimensional Design of a Reconfigurable PKM. International Journal of Advanced Robotic Systems, 2013, 10(10):799-811. DOI: 10.5772/54696.
Shao Zhu-Feng, Tang Xiaoqiang*, Wang Li-Ping, You Zheng. A Fuzzy PID Approach for the Vibration Control of the FSPM. International Journal of Advanced Robotic Systems, 2013, 10:59. DOI: 10.5772/53278.
Shao Zhu-Feng, Tang Xiaoqiang*, Wang Li-Ping. Optimum Design of 3-3 Stewart Platform Considering Inertia Property. Advances in Mechanical Engineering, 2013(5):1-10. DOI: 10.1155/2013/249121.
Liu Zhihua, Tang Xiaoqiang*, Shao Zhufeng, Wang Liping, Tang Lewei. Research on Longitudinal Vibration Characteristic of the Six-Cable-Driven Parallel Manipulator in FAST. Advances in Mechanical Engineering, 2013, 5(5):547416. DOI: 10.1155/2013/547416.
Shao Zhufeng, Tang Xiaoqiang*, Wang Li-Ping, Chen Xu. Dynamic modeling and wind vibration control of the feed support system in FAST. Nonlinear Dynamics, 2012, 67(2):965-985. DOI: 10.1007/s11071-011-0040-4 (SCI, EI)
Shao Zhu-Feng, Tang Xiaoqiang*, Chen Xu, Wang Li-Ping. Research on the inertia matching of the Stewart parallel manipulator. Robotics and Computer-Integrated Manufacturing, 2012, 28(6):649-659. DOI: 10.1016/j.rcim.2012.04.001 (SCI, EI)
Shao Zhufeng, Tang Xiaoqiang*, Chen Xu, Wang Liping. Driving force analysis for the secondary adjustable system in FAST. Robotica, 2011, 29(06): 903-915. DOI:10.1017/S0263574711000117 (SCI, EI)
Shao Zhufeng, Tang Xiaoqiang*, Chen Xu, Wang Liping. Inertia Match of a 3-RRR Reconfigurable Planar Parallel Manipulator. Chinese Journal of Mechanical Engineering, 2009, 22(6):791-799. DOI: 10.3901/CJME.2009.06.791 (SCI, EI)
姚铭, 段金昊, 邵珠峰*, 苑韶伦, 苏云州. 单舵轮AGV叉车的激光雷达定位与路径跟踪. 清华大学学报(自然科学版), 2024, 64(1): 117-129. Jan. 15, 2024. DOI: 10.16511/j.cnki.qhdxxb.2023.21.022
徐道春, 吕明青, 邵珠峰*, 陈涵玉, 胡益玮, 王传英. 基于改进复合三角函数的伺服压力机轨迹规划研究. 农业机械学报, 2023, 54(02): 450-458. Dec. 15, 2022. DOI:
罗勇, 邵珠峰*, 王立平, 丘嘉豪, 盛哲瑾. NL201HA数控卧式车床X轴热误差建模及补偿. 清华大学学报(自然科学版), 2021, 61(01): 28-35. June 17, 2020, DOI: 10.16511/j.cnki.qhdxxb.2020.22.022.
彭发忠, 张朋, 王立平, 邵珠峰*, 杨迪, 杨快. 基于飞轮转速自适应规划的伺服线能量管理. 清华大学学报(自然科学版), 2020, 60(11): 927-933. April 26, 2020, DOI: 10.16511/j.cnki.qhdxxb.2020.22.014.
彭发忠, 王传英, 柴恒辉, 邵珠峰*, 王帅奇, 王博文. 基于分层结构的伺服压力机滑块轻量化设计. 清华大学学报(自然科学版), 2020, 60(12): 1016-1022. May 22, 2020, DOI: 10.16511/j.cnki.qhdxxb.2020.22.016.
彭发忠, 段金昊, 邵珠峰*, 张兆坤, 王道明. 索驱动TBot及Delta高速并联机器人的性能对比分析. 清华大学学报(自然科学版), 2020: 1-10. December 22, 2020, DOI: 10.16511/j.cnki.qhdxxb.2020.26.027.
王立平, 张兆坤, 邵珠峰*, 王民. 机床制造加工数字化车间信息模型及其应用研究. 机械工程学报, 2019, 55(09):154-165. May 5, 2019, DOI: 10.3901/JME.2019.09.154.
刘志远, 陈炼, 邵珠峰*, 王立平, 唐晓强. FAST馈源支撑系统的终端精度保证研究. 机械工程学报, 2017, 53 (17): 50-59. September 5, 2017, DOI: 10.3901/JME.2017.17.050.
张兆坤, 邵珠峰*, 王立平, 赵钦志, 张云峰. 数字化车间信息模型及其建模与标准化. 清华大学学报(自然科学版), 2017(2):128-133. February 1, 2017, DOI: 10.16511/j.cnki.qhdxxb.2017.22.003.
李煜琦, 邵珠峰, 田斯慧, 唐晓强*. 基于吊丝配重的空间机械臂零重力模拟装置卸载率分析及评价. 机器人, 2016, 38(3) :293-300. May 1, 2016, DOI: 10.13973/j.cnki.robot.2016.0293.
王伟方, 唐晓强*, 邵珠峰. 八索立式储罐并联机器人设计及性能优化. 机械工程学报, 2016, 52(9) :1-8. May 5, 2016, DOI: 10.3901/JME.2016.09.001.
刘志华, 唐晓强*, 王立平, 邵珠峰. 射电望远镜馈源支撑系统的振动特性. 清华大学学报(自然科学版), 2013, 53(3):313-318. March 2013.
刘志华, 唐晓强*, 邵珠峰, 王立平. 6自由度索并联机构的振动特性. 机械工程学报, 2013, 49(3):49-55. February 5, 2013, DOI: 10.3901/JME.2013.03.049.
Li Jian, Tang Xiaoqiang*, Shao Zhufeng, Yao Rui. Hybrid position/force control strategy and experiment of the six-cable driven parallel manipulator for the forty-meter aperture radio telescope. High Technology Letters, 2012, 18(3):230-237. September 2012, DOI: 10.3772/j.issn.1006-6748.2012.03.002.
Chen Xu*, Shao Zhufeng, Tang Xiaoqiang, Feng Pingfa. Performance Simulation Analysis and Design of the Scale Model for the Earth Pressure Balance Shield. Advanced Materials Research, 2012, 346:364-371. DOI: 10.4028/ www.scientific.net/AMR.346.364 0,1.
柴晓明, 唐晓强*, 邵珠峰. 重心时变的多级混联支撑系统终端精度分析. 机器人, 2011, 33(5):546-552. September 2011, DOI: 10.3724/SP.J.1218.2011.00546.
邵珠峰*, 唐晓强, 王立平,黄鹏. 平面柔性3-RRR并联机构自标定方法. 机械工程学报, 2009, 45(3):150-155. March 2009, DOI: 10.3901/JME.2009.03.150 4,17.
Khan Muhammad Niaz, Lotfiani Amin, Javaid Umair, Shao Zhufeng. Mechanical Characterization Analysis of Kirigami Structure for Soft Robotic Design; proceedings of the 9th International Conference on Automation, Control and Robotics Engineering, CACRE 2024, July 18, 2024 - July 20, 2024, Jeju Island, Korea. [Web]
Wu Zhiyuan, Huo Ye, Ma Kangji, Song Yuanzeng, Sun Haiyan, Cao Huaizhi, Shao Zhufeng*. Innovative Design Research on a Cable-Driven Humanoid Robotic Arm; proceedings of the 9th International Conference on Automation, Control and Robotics Engineering, CACRE 2024, July 18, 2024 - July 20, 2024, Jeju Island, Korea. [Web]
Yao Ming, Chang Puikuan, Shao Zhufeng*, Zhang Qi, Niu Pengfei. Data-Driven Energy Consumption Modeling and Simulation Method of Discrete Manufacturing Workshop Based on Simplified Power Curve; proceedings of the 9th International Conference on Automation, Control and Robotics Engineering, CACRE 2024, July 18, 2024 - July 20, 2024, Jeju Island, Korea. [Web]
Zhou Xiang, Wu Xianzhi, Liu Hanqin, Shao Zhufeng*, Song Yuanzeng, Huang Minjian, Qie Jinbo, Cao Huaizhi. Design and Analysis of 7-DOF Cable-Driven Manipulator; proceedings of the 9th International Conference on Automation, Control and Robotics Engineering, CACRE 2024, July 18, 2024 - July 20, 2024, Jeju Island, Korea. [Web]
Mohamed, Elbeltagy; Shao, Zhufeng*; Yao, Ming; Zhang, Zhaokun. Intelligent Scalable and Fault-Tolerant Coordination Approach for Collective Construction Robots. // 2023 International Conference on Intelligent Robotics and Applications (ICIRA 2023), May 29-June 2, 2023, Hangzhou, China. [Web]
Duan Jinhao, Liu Hanqing, Zhang Zhaokun, Shao Zhufeng*, Meng Xiangjun, Lv Jingang, Huang Minjian. Reconfiguration and Performance Evaluation of TBot Cable-Driven Parallel Robot. CableCon 2023, 25-28 June 2023, Nantes, France. [Web]
Liu, Hanqing; Duan, Jinhao; Shao, Zhufeng*; Zhang, Zhaokun; Rao, Jing. Reachability analysis of a rigid-flexible cable robot for interior coating of tanker ships. // 2023 8th International Conference on Automation, Control and Robotics Engineering (CACRE 2023), July 13-15, 2023, Hong Kong, China. [Web]
Duan, Jinhao; Shao, Zhufeng*; Liu, Hanqing; Zhang, Zhaokun; Wang, Yujia; Zhao, Haili. Design analysis of a cable-driven parallel robot with parallel cables for ship side painting. // 2023 8th International Conference on Automation, Control and Robotics Engineering (CACRE 2023), July 13-15, 2023, Hong Kong, China. [Web]
Yao, Ming; Su, Yunzhou; Shao, Zhufeng*; Huo, Ye. Data-driven Energy Evaluation and Optimization Method for Industrial Robots. // 2023 8th International Conference on Automation, Control and Robotics Engineering (CACRE 2023), July 13-15, 2023, Hong Kong, China. [Web]
Ming Yao, Qinzhi Zhao, Zhufeng Shao*, Yanling Zhao. Research on power modeling of the industrial robot based on ResNet. // The 7th International Conference on Automation, Control and Robotics Engineering (CACRE), July 14-16, 2022, Xi’an, China. [Web]
Yao Ming, Shao Zhufeng, Yanlin Zhao. Review on energy consumption optimization methods of typical discrete manufacturing equipment. // The 14th International Conference on Intelligent Robotics and Applications (ICIRA), Oct. 22-25, 2021, Yantai, China. [Web]
Shan Zhang, Jinbo Qie, Shao Zhufeng, Zheng Sun. Workspace analysis of a mobile robot system for the ship section painting. // The 14th International Conference on Intelligent Robotics and Applications (ICIRA), Oct. 22-25, 2021, Yantai, China. [Web]
Ye Huo, Duan Jinhao, Shao Zhufeng, Hanqing Liu, Chunjiao Liu. Design and optimization of the new cable-driven ankle rehabilitation equipment. // The 14th International Conference on Intelligent Robotics and Applications (ICIRA), Oct. 22-25, 2021, Yantai, China. [Web]
Zhang Zhaokun, Shao Zhufeng*, Wang Liping, Luo Yong. Integration of Digital Equipment Based on General Information Model and Model Mapping to MTConnect. // ASME 2019 International Mechanical Engineering Congress and Exposition, IMECE 2019, November 11-14, 2019, Salt Lake City, UT, USA. [Web]
Amin Lotfiani, Yi Xili, Shao Zhufeng*, Liping. Wang. Research on Stiffness Improvement of a Soft Pneumatic Finger Using Skeleton.// 2019 IEEE International Conference on Real-time Computing and Robotics (RCAR). [Web] [PDF]
Shao Zhufeng, Yong Luo, Wang Liping, Zhang Zhaokun. Health Evaluation Method of CNC Machine Tools Based on Fuzzy Grey Clusteringand Combined Weighting Method. // IEEE Conference on Cyber Technology in Automation, Control, and Intelligent Systems (IEEE-CYBER), Jul. 29-Aug. 2, 2019, Suzhou, China. [Web] [PDF]
Shao Zhufeng, Peng Fazhong, Zhang Zhaokun, Li Haisheng. Research on the Dynamic Trajectory of Cable-Suspended Parallel Robot Considering the Uniformity of Cable Tension. // IEEE Conference on Cyber Technology in Automation, Control, and Intelligent Systems (IEEE-CYBER), Jul. 29-Aug. 2, 2019, Suzhou, China. [Web] [PDF]
Wang Liping, Chen Lian, Shao Zhufeng*, Zhang Zhaokun, Du Li. Stop Planning of Teleplatform for Large Civil Aircraft Painting with Industrial Robot. 2018 5th International Conference on Advanced Composite Materials and Manufacturing Engineering, ACMME 2018. June 16-17, 2018, Xishuangbanna, Yunnan, China, pp. 032064. [Web] [PDF]
Lotfiani Amin, Yi Xili, Zhao Qinzhi, Shao Zhufeng*, Wang Liping. Design and Experiment of a Fast-Soft Pneumatic Actuator with High Output Force. 11th International Conference on Intelligent Robotics and Applications, ICIRA 2018. August 9-11, 2018, Newcastle, NSW, Australia. Springer, Cham, 2018, 10984: 442-452. [Web] [PDF]
Wang Liping, Chen Lian, Shao Zhufeng*, Li Haisheng, Du Li. Modal parameter identification of the support frame of the high-speed pick-and-place cable-driven parallel robot, 2018 3rd International Conference on Insulating Materials, Material Application and Electrical Engineering, IMMAEE 2018. September 15-16, 2018, Melbourne, VIC, Australia. IOP Conference Series: Materials Science and Engineering, 2018, 452 (4):042011. [Web] [PDF]
Yuan Weitao, Zhang Zhaokun, Shao Zhufeng*, Wang Liping, Du Li. Performance Research of Planar 5R Parallel Mechanism with Variable Drive Configurations[C]// 10th International Conference on Intelligent Robotics and Applications, ICIRA 2017. August 16-18, 2017, Wuhan, China, pp. 15-18. [Web]
Zhang Zhaokun, Shao Zhufeng*, Wang Liping, Albert J Shi. Optimal Design of a High-Speed Pick-and-Place Cable-Driven Parallel Robot[C]// 3rd International Conference on Cable-Driven Parallel Robots, CableCon 2017. August 2 4, 2017, Quebec City, Canada, pp. 340-352. 7,6. [Web]
Wang Weifang, Tang Xiaoqiang*, Shao Zhufeng. Study on Energy Consumption and Cable Force Optimization of Cable-Driven Parallel Mechanism in Automated Storage/Retrieval System[C]// 2015 2nd International Conference on Soft Computing and Machine Intelligence, ISCMI 2015. November 23-24, 2015, Hong Kong, IEEE, pp. 144-150. 2, 3. [Web] [PDF]
Wang Liping, Li Haisheng, Shao Zhufeng*, Zhang Zhaokun, Peng Fazhong. Workspace Analysis of Cable Parallel Manipulator for Side Net Cleaning of Deep Sea Fishing Ground. International Conference on Cable-Driven Parallel Robots, 74,149-160. [Web]
| 编号 | 专利名称 | 专利号 | 类型 | 发明人 | 授权日期 |
|---|---|---|---|---|---|
| 01 | 具有轻量化高承载特性的索驱动混联码垛机器人 | 202210129542.3 | 专利 | 张兆坤, 邵珠峰, 段金昊, 霍晔, 刘汉擎 | 2024-01-30 |
| 02 | 防爆软体触碰传感器 | ZL202110801830.4 | 专利 | 邵珠峰, 尤政, 易希理, 安敏·骆, 段金昊, 霍晔 | 2024-03-26 |
| 03 | 可快速重构的移动式康复机器人 | ZL202310261310.8 | 专利 | 邵珠峰; 霍晔; 段金昊; 姚铭; 刘汉擎 | 2024-04-26 |
| 04 | 关节诊断康复一体设备 | ZL202322126327.0 | 专利 | 冉梓垠; 邵珠峰; 朱以明; 刘晓华; 唐鑫楠; 屠锋; 韩乾; 刘汉擎 | 2024-05-07 |
| 05 | 采用连续柔性体驱动的手部灵巧康复机器人 | ZL202211008164. | 专利 | 邵珠峰, 霍晔, 孔令杰, 段金昊 | 2024-05-28 |
| 06 | 一种轨道式柔性索驱钢筋绑扎机器人 | ZL202410622234.3 | 专利 | 陈凯; 桂峥嵘; 彭子祥; 邵珠峰; 蒙坤林; 刘汉擎; 杭旸; 黄浩宇 | 2024-07-19 |
| 07 | 面向船舶分段非结构面的超大空间喷涂装备及喷涂方法 | 202110777743. | 专利 | 邵珠峰, 段金昊, 尤政, 王立平, 郄金波, 霍晔, 彭发忠 | 2023-03-21 |
| 08 | 外骨骼支架组件和手臂支架组件及其制造方法 | 202310337437.3 | 专利 | 邵珠峰; 霍晔; 段金昊; 刘汉擎; 姚铭; 田海燕 | 2023-07-18 |
| 09 | 关节诊断康复一体设备和关节诊断康复方法 | 202310994613.0 | 专利 | 冉梓垠; 邵珠峰; 朱以明; 刘晓华; 唐鑫楠; 屠锋; 韩乾; 刘汉擎 | 2023-11-07 |
| 10 | 索驱动并联踝关节康复机器人 | ZL202111082033.1 | 专利 | 邵珠峰, 霍晔, 尤政, 段金昊, 姚铭, 刘春娇 | 2023-10-20 |
| 11 | 外骨骼支架组件和手臂支架组件 | CN202320688671.6 | 专利 | 邵珠峰;霍晔;段金昊;刘汉擎;姚铭;田海燕 | 2023-06-02 |
| 12 | 基于滑轮运动学的索并联机器人运动学标定方法 | 202011119308. | 专利 | 张兆坤, 邵珠峰, 彭发忠, 段金昊, 王立平 | 2022-04-26 |
| 13 | 工业机器人的能耗高效建模预测方法及装置 | CN202210334525.3 | 专利 | 邵珠峰, 姚铭, 段金昊, 霍晔, 刘汉擎 | 2022-07-22 |
| 14 | 平行索驱动的平面两自由度并联机器人 | CN202210066800.8 | 专利 | 邵珠峰, 张兆坤, 段金昊, 霍晔, 刘汉擎 | 2022-05-06 |
| 15 | 具有三维平动和一维转动的绳索驱动并联机器人 | CN202210068023.0 | 专利 | 张兆坤, 邵珠峰, 段金昊, 霍晔, 刘汉擎 | 2022-04-26 |
| 16 | 轻量化高速四自由度索驱动并联机器人 | CN202210068017.5 | 专利 | 邵珠峰, 段金昊, 张兆坤, 霍晔, 刘汉擎 | 2022-04-26 |
| 17 | 绳索驱动的高精度两自由度并联机器人 | CN202210068014.1 | 专利 | 张兆坤, 邵珠峰, 段金昊, 霍晔, 刘汉擎 | 2022-04-26 |
| 18 | 一种小型无人机恒张力供电系统 | 201910173288.5 | 专利 | 邵珠峰, 尤政, 彭发忠, 张兆坤, 邓豪, 李海圣 | 2021-04-27 |
| 19 | 一种内嵌骨架的软体气动手指 | 201910940206.5 | 专利 | 邵珠峰, 安敏·骆, 彭发忠, 张兆坤 | 2021-03-30 |
| 20 | 一种驱动方式可变的连杆支链及含该支链的并联机构 | 201711449714.0. | 发明专利 | 邵珠峰, 张兆坤, 王立平, 唐晓强, 邓豪 | 2020-02-03 |
| 21 | 一种高强板冲压成形回弹预测系统及方法 | 201711479583.0. | 发明专利 | 王立平, 张志刚, 邵珠峰, 马嵩华, 罗仁平, 贺亮, 邓豪, 张兆坤 | 2020-05-05 |
| 22 | 柔性支撑串联工业机器人作业最优初始位姿确定方法 | 201810289144.1. | 发明专利 | 邵珠峰, 陈炼, 王立平, 杜丽, 张兆坤, 李伟涛, 葛姝翌, 邓豪 | 2020-08-25 |
| 23 | 一种飞机整机自动化喷涂的片区划分和机器人站位规划方法 | 201810289182.7. | 发明专利 | 邵珠峰, 陈炼, 王立平, 陈洁, 杜丽, 邓豪, 张兆坤, 宋袁曾 | 2020-10-20 |
| 24 | 柔性支撑工业机器人的一种工作空间求解方法 | 201810291291.2. | 发明专利 | 邵珠峰, 陈炼, 王立平, 杜丽, 邓豪, 张兆坤, 葛姝翌, 李伟涛 | 2020-10-20 |
| 25 | 一种大型船舶分段自动化涂装系统 | 201810798002.8. | 发明专利 | 邵珠峰, 张兆坤, 王立平, 邓豪, 陈炼 | 2020-05-12 |
| 26 | 一种基于绳索的深海渔场侧网清洗及检测装置 | 201910349115.4. | 发明专利 | 邵珠峰, 李海圣, 王立平, 张兆坤, 彭发忠 | 2020-07-07 |
| 27 | 一种基于平面索并联机构的姿态优化方法 | 201910624629.6. | 发明专利 | 邵珠峰, 李海圣, 王立平, 张兆坤, 彭发忠, 王伟, 杜丽 | 2020-09-08 |
| 28 | 一种采用被动弹簧张紧的索驱动并联分拣机器人 | 201910667042.3. | 发明专利 | 邵珠峰, 张兆坤, 王立平, 彭发忠, 李海圣 | 2020-08-25 |
| 29 | 一种低质量长行程外墙喷涂装置 | 201910776685.1. | 发明专利 | 邵珠峰, 李海圣, 王立平, 张兆坤, 彭发忠, 谢光强 | 2020-06-02 |
| 30 | 一种船舶用索并联机器人超跨度喷涂轨迹规划方法 | CN108970868A. | 专利 | 邓豪, 邵珠峰, 尤政, 张兆坤, 彭发忠 | 2020-11-06 |
| 31 | 一种基于绳索的移动式巡检摄像装置 | 201910172707.3 | 专利 | 邵珠峰, 张兆坤, 王立平, 邓豪, 彭发忠, 李海圣 | 2020-10-27 |
| 32 | 一种基于平动约束结构的索并联装置 | 201610379730.6. | 发明专利 | 邵珠峰, 唐晓强, 王立平, 李彤宇, 张兆坤, 李煜琦, 夏圣悦 | 2019-01-29 |
| 33 | 一种防索并联机器人虚牵的检测装置 | 201710008134.1. | 发明专利 | 邵珠峰, 邓豪, 唐晓强, 王立平, 尤政, 张兆坤, 刘志远 | 2019-09-27 |
| 34 | 防索虚牵装置及包含该装置的冗余驱动并联机器人 | 201710008132.2. | 发明专利 | 邵珠峰, 邓豪, 王立平, 唐晓强, 尤政, 张兆坤, 陈炼 | 2019-03-22 |
| 35 | 一种制造软体机器人的模具及方法 | 201810448310.8. | 发明专利 | 王立平, 安敏·骆, 邵珠峰, 邓豪, 张兆坤, 吴超 | 2019-06-04 |
| 36 | 一种具有重心调整功能的模块化旋转驱动单元 | 201410357304.3. | 发明专利 | 唐晓强, 邵珠峰, 唐乐为, 田斯慧, 王伟方, 曹凌, 季益中 | 2018-08-17 |
| 37 | 一种驱动关节可变的RRR并联机构支链装置 | 201610803243.8. | 发明专利 | 邵珠峰, 关立文, 袁伟涛, 王立平, 张兆坤, 邓豪, 刘志远 | 2018-06-15 |
| 38 | 一种模拟火箭发射的索机构实验装置 | 201410608347.4. | 发明专利 | 唐晓强, 邵珠峰, 曹凌, 汪劲松, 季益中, 王伟方, 田斯慧, 李煜琦 | 2017-04-19 |
| 39 | 一种上支撑式空间四索超跨度机器人 | 201510818727.5. | 发明专利 | 唐晓强, 邵珠峰, 田斯慧, 汪劲松, 刘辛军, 李煜琦, 祝玉兰, 季益中, 项程远, 刘振辉 | 2017-03-22 |
| 40 | 索并联驱动的高速多体机构 | 201610262564.1. | 发明专利 | 邵珠峰, 唐晓强, 王立平, 夏圣悦, 袁伟涛, 李彤宇, 莫艽 | 2017-11-21 |
| 41 | 一种具有蓄能缓冲功能的高速重载搬运机构 | 201611071303.8. | 发明专利 | 唐晓强, 邵珠峰, 崔志伟, 季益中, 李铁民, 姜峣, 侯森浩, 田斯慧, 项程远, 李煜琦 | 2017-12-19 |
| 42 | 一种用于精密装配的两级并联机器人装置 | 201410105598.0. | 发明专利 | 邵珠峰, 尤政, 王立平, 唐晓强, 张兆坤, 刘志华, 高东川, 王长伟 | 2016-08-17 |
| 43 | 一种用于水运仪象台的传动装置及传动齿数配比设计方法 | 201410143590.3. | 发明专利 | 唐晓强, 邵珠峰, 王伟方, 季益中, 刘志华, 唐乐为, 曹凌 | 2016-07-13 |
| 44 | 一种基于索并联构型的河道清淤机构 | 201410395740. | 发明专利 | 刘辛军, 邵珠峰, 唐晓强, 王长伟, 张东亚 | 2016-08-24 |
| 45 | 一种模拟零重力及低重力环境的索驱动机器人装置 | 201410584915.1. | 发明专利 | 唐晓强, 邵珠峰, 王伟方, 汪劲松, 曹凌, 王长伟, 田斯慧, 李煜琦, 张欢 | 2016-06-15 |
| 46 | 一种模拟零重力和低重力的九索驱动机器人装置 | 201410584138.0. | 发明专利 | 唐晓强, 邵珠峰, 王伟方, 汪劲松, 曹凌, 季益中, 田斯慧, 李煜琦 | 2016-05-18 |
| 47 | 一种大型立式储罐检修用索并联机器人 | 201410638501.2. | 发明专利 | 唐晓强, 邵珠峰, 王伟方, 汪劲松, 曹凌, 季益中, 田斯慧, 李煜琦 | 2016-01-20 |
| 48 | Spindle Head Structure Rotatable in A/B Axes | US874892B2 | 发明专利 | Tang Xiaoqiang, Wang Liping, Shao Zhufeng, Wang Dianjun, Yao Rui, Qu Lin | 2014-05-06 |
| 49 | 一种空间并联机构的被动重力补偿支链 | 201310064015. | 发明专利 | 邵珠峰, 唐晓强, 唐乐为, 王伟方, 刘志华 | 2014-12-24 |
| 50 | 一种绳索驱动的外骨骼式上肢康复机器人系统 | 201410038145.0. | 发明专利 | 邵珠峰, 唐晓强, 王立平, 王伟方, 刘志华 | 2014-07-09 |
| 51 | 一种电缆与绳索主动吊挂装置 | CN201010145149.0. | 发明专利 | 唐晓强, 姚蕊, 黄鹏, 邵珠峰, 李剑, 赵海平 | 2012-05-09 |
| 52 | 一种电缆与绳索被动吊挂装置 | 201010145153.7. | 发明专利 | 唐晓强, 姚蕊, 赵海平, 邵珠峰, 李剑, 黄鹏 | 2012-05-09 |
| 53 | 一种CAC轴复合化铰链 | 201010162850.3. | 发明专利 | 唐晓强, 李铁民, 李剑, 邵珠峰, 姚蕊, 赵海平, 柴晓明 | 2012-06-20 |
| 54 | 一种落地式电动控制伸缩的投影幕支架 | 201010199150.1. | 发明专利 | 唐晓强, 邵珠峰, 季益中, 陈旭, 姚蕊, 李剑, 赵海平, 柴晓明 | 2012-05-23 |
| 55 | 大型射电望远镜主动反射面共驱动并联机构阵列 | 200710177308.3. | 发明专利 | 唐晓强, 汪劲松, 黄鹏, 姚蕊, 邵珠峰 | 2011-01-26 |
| 56 | 带约束支链的平面并联机构及其拓展机械手装置 | 200710177514.4. | 发明专利 | 唐晓强, 汪劲松, 邵珠峰, 姚蕊, 黄鹏 | 2010-09-29 |
| 57 | 一种用伸缩支链驱动的串联式A/B轴主轴头结构 | 200810115635.0. | 发明专利 | 唐晓强, 王立平, 邵珠峰, 王殿君, 姚蕊, 屈林 | 2010-06-02 |
| 58 | 一种绳索并联机构自动跟踪转向传动装置 | 200810116770.7. | 发明专利 | 唐晓强, 汪劲松, 姚蕊, 邵珠峰, 屈林 | 2010-06-02 |
| 59 | 大型射电天文望远镜馈源定位平台自平衡机构 | 200710122572.7. | 发明专利 | 唐晓强, 汪劲松, 姚蕊, 黄鹏, 邵珠峰 | 2009-12-16 |
| 60 | 一种电缆收放装置 | 200810115894.3. | 发明专利 | 唐晓强, 汪劲松, 屈林, 赵天宇, 邵珠峰, 姚蕊 | 2009-12-09 |
| 编号 | 标准名称 | 标准号 | 标准类型 | 发布日期 | 实施日期 |
|---|---|---|---|---|---|
| 01 | 数字化车间 机床制造 信息模型 | GB/T 37928-2019 | 国家标准 | 2019-08-30 | 2020-03-01 |
| 02 | 数控装备互联互通及互操作 第一部分: 通用技术要求 | GB/T 39561.1-2020 | 国家标准 | 2020-12-14 | 2021-07-01 |
| 03 | 数控装备互联互通及互操作 第2部分:设备描述模型 | GB/T 39561.2-2020 | 国家标准 | 2020-12-14 | 2021-07-01 |
| 04 | 数控装备互联互通及互操作 第 3部分:面向实现的模型映射 | GB/T 39561.3-2020 | 国家标准 | 2020-12-14 | 2021-07-01 |
| 05 | 数控装备互联互通及互操作 第7部分:工业机器人测试与评价 | GB/T 39561.7-2020 | 国家标准 | 2020-12-14 | 2021-07-01 |
| 06 | 制造装备集成信息模型通用建模规则 | GB/T 40209-2021 | 国家标准 | 2021-05-21 | 2021-12-01 |
| 07 | 数控机床远程运维 第1部分:通用要求 | GB/T 42707.1-2023 | 国家标准 | 2028-08-06 | 2024-03-01 |
| 08 | 数控机床远程运维 第2部分:故障诊断与预测性维护 | GB/T 42707.2-2024 | 国家标准 | 2024-10-26 | 2025-05-01 |
| 编号 | 软件名称 | 登记号 | 著作权人 | 登记日期 |
|---|---|---|---|---|
| 01 | 邵珠峰 | 2017SR002830 | 邵珠峰, 莫艽, 关立文. 高速并联机构性能分析优化软件, 2017SR002830 | 2016-11-04 |
| 02 | 邵珠峰 | 2019SR0788606 | 邵珠峰, 张兆坤, 王立平, 彭发忠. 面向MTConnect的数控装备信息模型映射软件. 2019SR0788606 | 2019-06-12 |
| 03 | 邵珠峰 | 2019SR0794600 | 邵珠峰, 罗勇, 张兆坤, 王立平. 数控机床可靠性数据采集系统. 2019SR0794600 | 2019-06-14 |
| 04 | 邵珠峰 | 2019SR0935869 | 邵珠峰, 罗勇, 张兆坤, 王立平, 杜丽. 数控机床振动数据分析处理软件. 2019SR0935869 | 2019-08-28 |
| 05 | 邵珠峰 | 2020SR1235708 | 邵珠峰, 张兆坤, 尤政, 王立平, 段金昊. 索并联机器人示教与轨迹测试软件. 2020SR1235708 | 2020-10-21 |
| 06 | 邵珠峰 | 2020SR1235705 | 邵珠峰, 张兆坤, 王立平, 唐晓强, 段金昊. 索并联机器人分拣控制软件. 2020SR1235705 | 2020-10-21 |
| 07 | 邵珠峰 | 2020SR1233792 | 邵珠峰, 张兆坤, 尤政, 王立平, 彭发忠. 索并联机器人运动学标定及精度检验软件, 2020SR1233792 | 2020-10-20 |
| 08 | 邵珠峰 | 2020R11S2269821 | 邵珠峰, 彭发忠, 王传英, 柴恒辉, 段金昊. 六连杆压力机运动分析与尺度优化软件. 2020R11S2269821 | 2020-11-18 |
| 09 | 邵珠峰 | 2021SR1516084 | 邵珠峰, 霍晔, 尤政, 段金昊, 姚铭. 基于磁尺网格的AGV运动轨迹规划控制软件. 2021SR1516084 | 2021-10-15 |
| 10 | 邵珠峰 | 2021SR1516085 | 邵珠峰, 段金昊, 尤政, 霍晔, 姚铭. 磁尺舵轮背负式AGV运动控制软件. 2021SR1516085 | 2021-10-15 |
| 11 | 邵珠峰 | 2021SR1520145 | 邵珠峰, 尤政, 姚铭, 段金昊 | 2021-10-15 |
| 12 | 邵珠峰 | 2022SR0390320 | 邵珠峰, 霍晔, 段金昊, 姚铭 | 2022-04-06 |
| 13 | 邵珠峰 | 2023SR0888263 | 邵珠峰,姚铭,苏云州,段金昊,霍晔 | 2023-05-25 |
| 14 | 邵珠峰 | 2023SR1039031 | 邵珠峰,姚铭,苏云州,霍晔,段金昊 | 2023-05-25 |
| 15 | 邵珠峰 | 2024SR0055582 | 邵珠峰,姚铭,段金昊,霍晔 | 2023-10-26 |
| 16 | 邵珠峰 | 2024SR0272379 | 邵珠峰,段金昊,姚铭,霍晔,刘汉擎,黄敏健(校外),饶靖(校外) | 2024-02-18 |
| 17 | 邵珠峰 | 2024SR0282469 | 邵珠峰,段金昊,刘汉擎,姚铭,霍晔,黄敏健(校外) | 2024-02-20 |
| 18 | 邵珠峰 | 2024SR0282309 | 邵珠峰,段金昊,霍晔,姚铭,刘汉擎,董亮(校外) | 2024-02-20 |
| 19 | 邵珠峰 | 2024SR0315514 | 邵珠峰,姚铭,段金昊,霍晔 | 2024-02-27 |
| 20 | 邵珠峰 | 2024SR0384156 | 邵珠峰,段金昊,姚铭,刘汉擎,霍晔,饶靖(校外) | 2024-03-13 |
清华大学出版社 · 2020
围绕索驱动及刚性并联机构的基础理论、分析方法及工程应用展开系统论述。
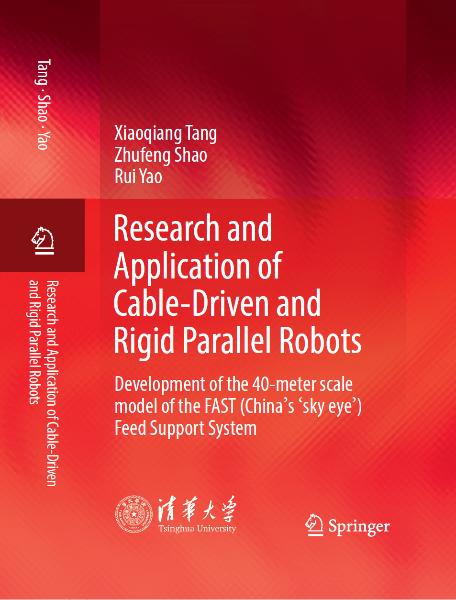
Springer · 2021
系统介绍索驱动与刚性并联机器人的理论、设计方法及相关工程应用。
中国机械工业科学技术奖,技术发明一等奖
2024中国专利银奖
2021“中国仪器仪表学会科学技术奖”技术发明一等奖(1/6)
2020“中国机械工业科学技术奖”科技进步特等奖和二等奖(1/10)
2020全国机械工业设计创新大赛金奖
2020首届《清华大学学报(自然科学版)》年度优秀论文奖
2020中国产学研创新奖(个人奖)
2019教育部自然科学二等奖(6/8)
20152014中国机械工业科技进步特等奖(12/35)
2014清华大学SRT优秀指导教师一等奖和二等奖
2020清华大学年度优秀博士学位论文(张兆坤)
2020清华大学年度优秀本科毕业论文(段金昊)
2020北京高校青年教师教学基本功比赛工科类A组 二等奖
2019清华大学青年教师教学比赛(工科组) 一等奖
2018清华大学教学优秀奖
2017清华大学年度优秀本科毕业论文(莫艽)
2015清华大学年度教育成果二等奖“并联机器人创新设计教学实践”(邵珠峰,第5完成人)
2014